ArduPilot SITL: UDS support
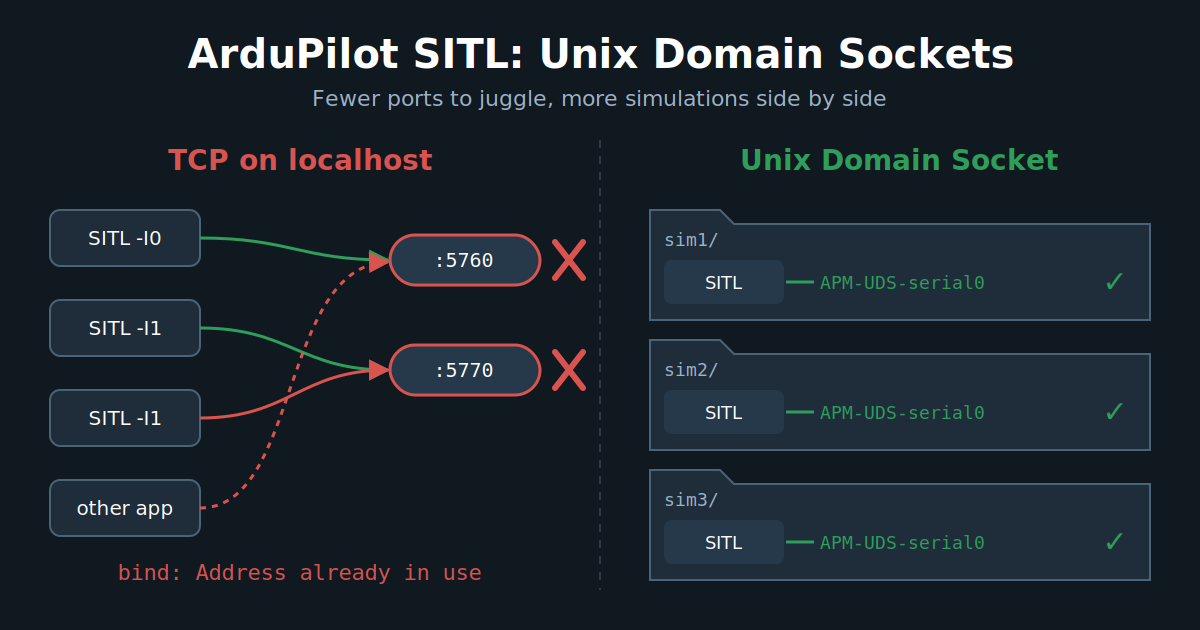
ArduPilot simulation is simple and complex at the same time, since we support a lot of features. We obviously allow testing all the vehicle types we support, but what is less known is that we can simulate different sensors, such as GNSS, compass or eAHRS, with their real protocol AND their physical bus: SPI, I2C, UART, CAN. That's right, we have a virtual CAN bus, but also I2C and SPI simulation! That is quite convenient for developers, but less useful for most users. Running one SITL is easy. Running dozens of SITLs is where TCP ports start becoming annoying, as we need to manage the ports numbering, collisions and we start seeing congestion and TCP/UDP limits !
Recently, we integrated support for a new way to communicate with the simulation instance: UDS (Unix Domain Socket) !